As industrial automation continues to demand higher speed, positioning accuracy, and repeatability, traditional mechanical transmission systems are not always the best choice for every application. A linear motor stage provides a direct-drive approach to linear motion, making it suitable for equipment that requires fast and precisely controlled movement.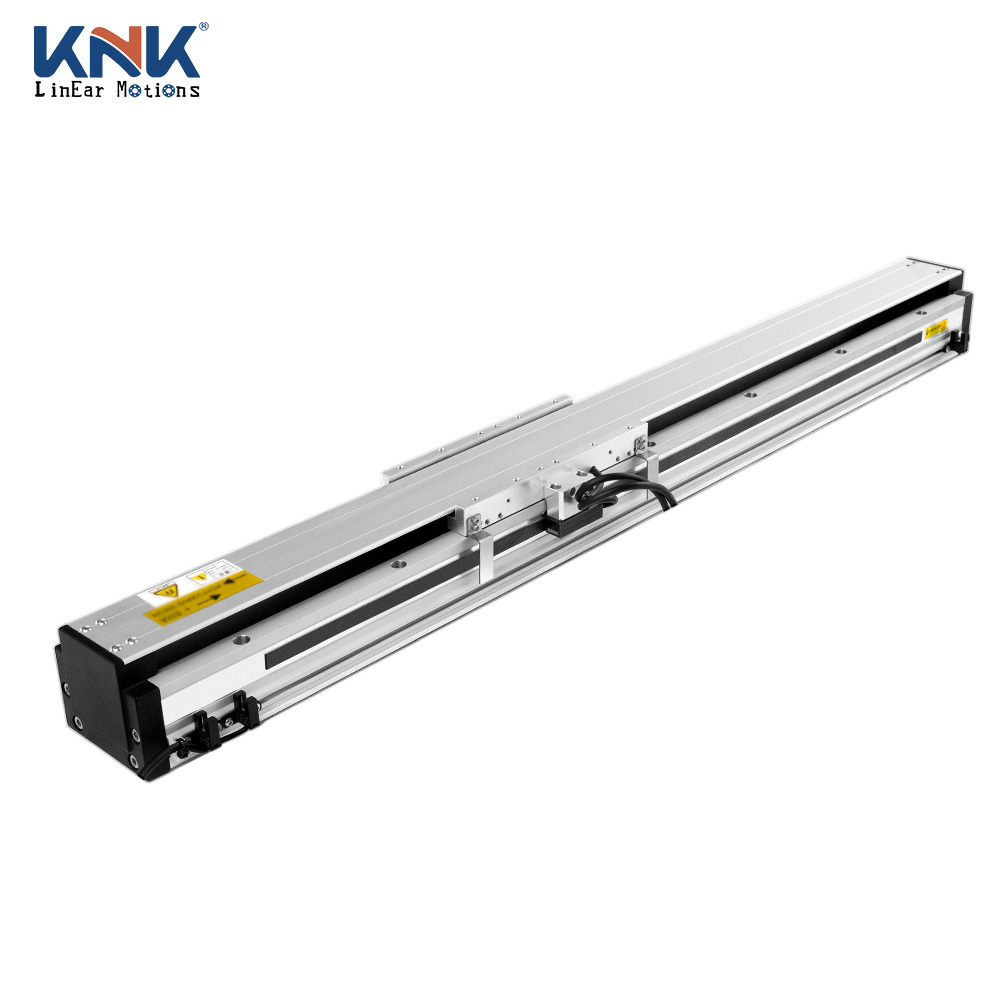
Unlike belt-driven or screw-driven linear stages, a linear motor stage generates linear force directly through electromagnetic interaction. This eliminates the need for a conventional screw or belt transmission between the motor and moving platform.
For OEM machine builders and automation integrators, this structure can provide advantages in high-speed positioning, acceleration, smooth motion, repeatability, and multi-axis integration.
A customized linear motor stage can also be configured according to the required travel, payload, speed, acceleration, positioning accuracy, mounting dimensions, feedback system, and control architecture.
A linear motor stage is a precision linear motion system that combines a linear motor with a guide mechanism and position feedback system.
A typical system may include:
The basic operating principle is:
Electrical Energy → Electromagnetic Force → Direct Linear Motion
Instead of converting rotary motion into linear motion through a screw, gear, or belt, the linear motor produces linear force directly.
This makes the technology particularly attractive for applications where high speed, high acceleration, smooth movement, and precise positioning are important.
One of the most important characteristics of a linear motor stage is its direct-drive structure.
A conventional system may use:
Motor → Screw/Belt → Linear Motion
A linear motor stage uses:
Motor → Direct Linear Force → Linear Motion
Because the system does not require a conventional mechanical transmission, it can reduce transmission-related mechanical limitations.
This makes linear motor stages suitable for demanding motion applications.
Linear motor stages are often selected for applications requiring high linear velocity.
Without a conventional screw or belt transmission, the motion system can be designed for high-speed operation.
Typical applications include:
The actual maximum speed depends on the motor, guide system, payload, stroke, controller, encoder, and machine structure.
A linear motor stage can provide rapid acceleration and deceleration.
This is useful when the machine repeatedly moves between multiple positions within a short cycle time.
For example:
Position A → High-Speed Movement → Deceleration → Position B → Return
High acceleration can help reduce cycle time, especially in pick-and-place, inspection, and precision manufacturing equipment.
However, payload and mechanical rigidity must be considered when determining the appropriate acceleration.
A linear motor stage can be integrated with a high-resolution linear encoder for closed-loop position feedback.
The controller continuously receives position information and adjusts the motor accordingly.
This makes the technology suitable for applications requiring:
Actual positioning accuracy depends on the complete system, including the encoder, guide, mechanical structure, thermal conditions, controller, and installation.
The direct-drive structure can provide smooth motion without the mechanical backlash associated with certain transmission systems.
This can be beneficial for:
Smooth movement can also help reduce unwanted vibration during sensitive operations.
Traditional screw, gear, and belt systems can introduce mechanical transmission effects such as backlash, elastic deformation, or belt compliance.
A linear motor stage eliminates the conventional mechanical transmission between motor rotation and linear movement.
This can simplify the motion chain and help achieve high dynamic performance.
However, guide accuracy, mounting rigidity, encoder resolution, and machine structure still influence the final positioning performance.
Linear motor stages can be integrated into multi-axis systems.
For example:
X Linear Motor Stage + Y Linear Motor Stage + Z Axis
This can create a high-performance Cartesian motion platform.
Potential applications include:
Both systems can provide precise linear motion, but they have different characteristics.
| Feature | Linear Motor Stage | Screw-Driven Stage |
|---|---|---|
| Drive Method | Direct linear drive | Rotary motor + screw |
| Speed | Very high potential | Application dependent |
| Acceleration | High potential | Application dependent |
| Backlash | No screw transmission backlash | Depends on screw/nut system |
| Mechanical Transmission | Minimal | Screw required |
| Precision | Excellent potential | Excellent |
| Maintenance | Low mechanical transmission wear | Screw/nut maintenance required |
| Long-Term High-Speed Operation | Suitable for many applications | Thermal considerations may become important |
| Cost | Generally higher | Often more economical |
A screw-driven stage may be the better choice for applications where high thrust, moderate speed, and cost efficiency are priorities.
A linear motor stage becomes more attractive when speed, acceleration, smooth motion, and dynamic positioning performance are critical.
Semiconductor manufacturing requires extremely precise motion.
Linear motor stages can be used for:
The combination of direct drive and encoder feedback can support high-performance positioning.
Electronic components often require fast and repeatable positioning.
Linear motor stages can be integrated into:
High acceleration can be particularly useful for reducing machine cycle time.
Automated vision systems may need to move cameras or products rapidly between inspection points.
A linear motor stage can provide:
Fast Travel → Accurate Deceleration → Precise Positioning → Inspection
This can be useful for multi-point inspection systems where cycle time is important.
Laser processing equipment may require precise movement of the workpiece or laser head.
Applications include:
The motion system needs to be matched to the laser process requirements, including speed, acceleration, positioning accuracy, and path control.
Linear motor stages can position dispensing heads with high dynamic performance.
Applications include:
For multi-axis dispensing machines, several linear motor stages can be combined to create a customized motion platform.
Linear motor stages can be used in high-speed pick-and-place systems.
A typical sequence is:
Move → Accelerate → Position → Pick → Move → Place
The high acceleration capability of linear motors can help shorten the movement portion of the machine cycle.
For applications with lower speed requirements, belt-driven or screw-driven linear modules may provide a more cost-effective solution.
Measurement systems often require stable and repeatable positioning.
Linear motor stages can be used for:
Encoder feedback can provide real-time position information to the control system.
Laboratory equipment increasingly uses automated linear positioning.
Linear motor stages can be applied to:
Customized dimensions and motion parameters can be useful when the equipment has a unique mechanical structure.
Standard linear motor stages may not always match the requirements of custom machinery.
OEM customers may require different:
A custom linear motor stage can be designed around the complete application.
For example, an OEM customer may require a compact stage with a short stroke and extremely high acceleration, while another machine may need a longer travel range with a larger payload.
The two applications may require completely different configurations.
Before choosing a linear motor stage supplier, engineers should evaluate several key parameters.
Determine the required travel distance.
The stroke affects the motor configuration, guide system, encoder, cable management, and overall machine size.
Calculate the complete moving mass, including:
Determine the required maximum linear velocity.
The required speed should be considered together with the stroke and cycle time.
Acceleration is particularly important for high-speed applications.
A higher payload combined with high acceleration requires greater motor force.
Determine whether the application requires:
The encoder, guide, mounting structure, controller, and thermal environment all influence final performance.
Determine how frequently the stage operates.
For example:
Thermal management and motor sizing should be evaluated accordingly.
Consider:
Special environmental requirements may affect the selection of the guide, encoder, motor, and protective structure.
For OEM automation systems, customization may include:
Designed according to the required travel.
Motor force and guide configuration can be selected according to the moving mass.
The feedback system can be selected according to positioning requirements.
The mechanical interface can be adapted to the customer's equipment.
The linear motor can be selected according to speed, force, acceleration, and duty cycle.
Multiple stages can be combined to create X-Y or X-Y-Z positioning systems.
A customized system can combine several linear motor stages.
For example:
X Axis → Y Axis → Z Axis
The X and Y axes provide horizontal positioning while the Z axis performs vertical movement.
A more advanced system can include:
Linear Motor Stage + Vision System + Servo Control + Encoder + PLC
This type of configuration can be used for high-speed precision automation.
When requesting a custom linear motor stage, it is useful to provide:
With this information, a manufacturer can evaluate the complete motion requirements rather than selecting a stage based on only one specification.
For standard applications, an off-the-shelf stage may be sufficient.
For OEM machinery, however, the motion stage often needs to integrate directly with the customer's mechanical and electrical architecture.
A suitable linear motor stage manufacturer should be able to provide:
This approach can reduce compatibility issues during machine integration.
Linear motor stages are suitable for many industries, including:
A linear motor stage is a high-performance linear motion solution designed for applications requiring fast, smooth, and precisely controlled movement.
Its key features include direct-drive motion, high-speed capability, high acceleration, low transmission backlash, smooth movement, encoder-based feedback, and flexible multi-axis integration.
Linear motor stages can be used in semiconductor equipment, electronics manufacturing, vision inspection, laser processing, precision dispensing, pick-and-place systems, measurement equipment, and laboratory automation.
For OEM customers, customization is particularly important. The stage can be configured according to stroke, payload, speed, acceleration, positioning accuracy, repeatability, encoder, mounting dimensions, duty cycle, and environmental conditions.
The best linear motor stage is not necessarily the one with the highest specifications. It should be the one that matches the complete machine requirements while balancing performance, reliability, integration complexity, and cost.
For high-speed and precision automation, a properly designed custom linear motor stage can provide the dynamic performance needed for modern industrial motion systems.